Features
Back to Library >
Meet the Antis
2 years ago

Even so, it’s clear we do not want too much dive or squat, which is why chassis engineers have devised methods to control them, the geometric ones being called anti-dive and anti-squat, often summarily talked about as ‘the Antis’. Sounds like a cartoon television family. But it’s not. The more complicated case is braking, so we’ll deal with that first and towards the end look at acceleration.
Obviously this force is generated in the brakes and the tyres transmit it to the road surface. So the braking force attacks at the contact patch both towards the road in the one direction – hence the surface damage where lorries brake – and onto the car in the other, slowing it down (red arrows in Pic B).

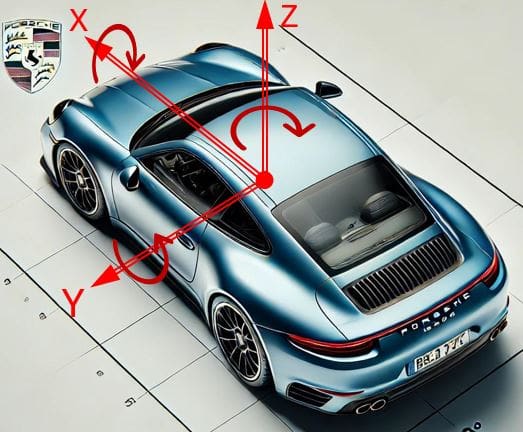
The equal and opposite inertial force of slowing down the car attacks at the car’s centre of gravity (‘CoG’, green arrow). That is always at a certain height above ground: usually in the range of 40-80cm in a passenger car. Thus these forces create a rocking couple that wants to rotate the car forward around the lateral or Y axis. As there are only the tyres’ contact patches to counter this couple, it increases the wheel loads at the front axle and reduces it at the rear (grey arrows).
This is the effect that talented and experienced drivers can use to help the car turn in as ‘trail braking’ or to tuck into the curve by merely brushing the brakes. In the extreme, however, this may lead to brake-induced oversteer and even spinning (watch old American movies like The Blues Brothers to see what I mean). The extent of this – and its limits – also depend very much on brake force distribution and the setup of the ABS and ESC systems, but this takes us too far from our subject and provides me with the perfect excuse for another overly nerdy story at some stage in the future. So back to the main event.
Obviously the more we increase the load at the front and conversely unload at the rear, the more the front springs are compressed and those at the rear extended. Simple, isn’t it? Well, actually no, for like all things in dynamics this is neither simple, nor the whole story. For the spring to react to the force it must be compressed by the corresponding amount, so some motion is required. The shock absorber on the same wheel builds force in response to the velocity with which the wheel moves up or down relative to the body; in this case the body moving down at the front and up at the rear. This is a more immediate response to a car’s deceleration than springs can provide but still requires some motion. Indeed well-tuned dampers have a profound effect on the perception of drivers and passengers of the brake-dive behaviour of any car.

"These two forces only respond to the reaction(!) of the car to braking. In other words the vehicle first has to move before they even begin to stem the dive. The most immediate force to counteract it, however, is one that is created directly by the brake force itself. This is a characteristic of the suspension called ‘anti-dive’"
The two points just discussed – springs and dampers – also explain why the car feels more ‘planted’ while braking when you change the factory springs and dampers for a more sporting uprated set. Lowering the car – as sports springs tend to do – also goes a little way to lowering the centre of gravity, thus reducing brake-dive.
Still these two forces only respond to the reaction(!) of the car to braking. In other words the vehicle first has to move before they even begin to stem the dive. The most immediate force to counteract it, however, is one that is created directly by the brake force itself. This is a characteristic of the suspension called ‘anti-dive’, which the chassis engineer can use to his or her advantage. If left to chance or sacrificed to serve package restraints or other boundary conditions it may also turn to their disadvantage. We’ll come back to that point.
We usually think of wheel motion in bump and droop as the wheel going vertically up and down, but this is rarely the case in real car suspension systems: both the wheel’s centre point and the tyre road contact patch move at small angles or arc relative to the pure vertical. This is sometimes called kinematic precession or recession and determines both the anti-dive (at the contact patch) and anti-squat (at the wheel center). As far as the wheel centre is concerned it also has a strong influence on rolling harshness.
In Pic B above, this is shown for a double wishbone front suspension and a trailing arm rear suspension.
“The chassis designer has various ways of setting or determining the anti-dive characteristics of both the front and the rear suspension. First and most obviously is the choice of type of suspension itself. In some the characteristics are pretty much defined by the type alone. In other more sophisticated suspension types the design engineer is at great freedom to determine them”
The most important point for braking is that the brake force acts horizontally at the contact patch, but through the angle of the direction of motion a vertical component is created (light blue arrows in Pic B) together giving the resultant force (dark blue arrow in Pic C). This is very much like what athletes do in the pole vault, where their forward momentum is redirected upwards by the angle of the pole and catapults them up and (hopefully) above the crossbar. In Pic B the ‘pole’ is symbolised by the solid black line on the front suspension. In Pic C it is the lower green dashed line.

An example for a front suspension (here a double wishbone, but the same principle for all) is shown in Pic C; the colours are the same as in Pics B and D. The motion centre is defined here by the upper and lower wishbones and their angles in side view (dark blue dashed lines). The contact patch and wheel centre also move around it (green dashed lines). The anti-dive effect is created by the reaction of the braking force. For driven wheels the same happens at the wheel centre (forces not shown here) as reaction to the driving force.

The chassis designer has various ways of setting or determining the anti-dive characteristics of both the front and the rear suspension. First and most obviously is the choice of type of suspension itself. In some the characteristics are pretty much defined by the type alone, such as on twist beams or semi-trailing arm rear suspensions. In other more sophisticated suspension types the design engineer is at great freedom to determine them, such as in the classic double wishbone (as in Pics B, C and E) or modern multilink designs.
Pic E shows the percentages of anti-dive for front and rear suspension on the scale in the middle of the car. Rear is 80 per cent, which is good. The front is 85 per cent, which is excessive, as we will see later. Point D is the dive centre, defined as where the extensions of the lines of both axles, from their contact patches to their respective motion centres, intersect.

It should be said here that neither the brake-dive itself nor all the measures taken against it change the wheel load transfer under braking: this is determined purely by the deceleration and the height of the centre of gravity in relation to the wheelbase.
The limit of brake-dive at the front axle in modern cars is usually set by the bump stops, these days usually long polyurethane ‘helper springs’, as the wheel reaches the end of the suspension travel.
Once again this is a prime application for ‘systems engineering’: the brake-dive behaviour you want as a whole vehicle characteristic (often expressed as degrees of dive per g and, more sophisticated, as vertical driver motion in millimetres per g) needs to fulfil the vehicle targets hopefully derived from customer preference. Other vehicle characteristics, predominantly the height of the centre of gravity and dynamic brake-force distribution, have a strong influence, of course. From these the targets for anti-dive values are derived, also taking into account target spring rates and damping. As suspension characteristics are so fundamental, it is very difficult – not to mention costly and time consuming – to change them later in the development stage, where typically not much more than spring rates and damper valving can be tuned.
So now a question, and ultimately the only one that matters here: what is good dive behaviour? Common sense suggests no dive whatsoever is the ideal. But what does common sense know about vehicle dynamics or human perception? Very little it seems. Instead, scientific and customer studies as well as the perception of experienced vehicle dynamics evaluators seem to show the following to be desirable:
– A small amount of dive angle, because a large change in angle is perceived through the motion organs and exaggerated by the line of sight contributing to an unsettled feeling
– The drivers and passengers moving down somewhat, which gives the (physically incorrect) feeling of the car ‘grabbing’ at the road
– And that motion should be well damped without large overshoots
At the system level this usually requires a small amount of anti-dive in the front (such as 15 per cent) and much more in the rear, in some cases more than full (100 per cent), meaning the rear moving down rather than up and the car really hunkering down on the road.


As early as the 1960s much was made in advertising of ‘Anti-Dive Geometry’ made possible by the work of that great Welsh chassis engineer Maurice Olley. On most American cars this simply meant that on the usual double wishbone front suspension, the upper and lower wishbones’ body side attachments were angled somewhat to give the desired effect as shown here in Pics B, C and E. With the quite soft chassis setup popular in that time that was quite effective, but was somewhat spoiled by the lack of anti-dive in most solid rear suspension systems.
I myself have had to deal with a much more recent particular model, where the rear suspension had basically no anti-dive and the chassis designers tried to compensate by having a very large amount at the front. As a result the front hardly went down while the rear came up a great deal and very swiftly. So the dive angle was still large and all on board were lifted up. Making things worse were the rather comfort-oriented springs and dampers. The feeling when you got on the brakes was that of a bucking bronco trying to throw you over the front.

Whether by design or by sheer luck many C Class (‘Golf’ class) cars are actually quite good in the front to rear balance of anti-dive, simply by virtue of the fact that the typical MacPherson strut front suspension – if executed correctly – readily offers the desired small amount of anti-dive even together with some kinematic wheel recession to reduce harshness. At the same time most rear suspensions in this category naturally offer a good amount of anti-dive, sometimes exceeding 100 per cent. Prime examples are the ubiquitous twist beam, the ‘French’ trailing arms and the ‘Control Blade’ multilink rear suspension first used on the Ford Focus and subsequently by many others. It was actually one of the decisive criteria to use the Control Blade over the alternative design proposals.

The converse to brake-dive, of course, is lift and squat while the car is accelerating, lifting the front while lowering the rear as outlined above. In principle everything already described about braking applies here, only with the forces all going the other way. Only the driven wheels are affected, so in most cases it is not all four. The case is rather simple on rear-wheel drive cars, where everything wants to go the same way: you want the contact patch to move rearwards for brake anti-dive, you want the centre to (somewhat) move rearwards for anti-squat and you also want it to move rearwards by a small amount for harshness. So at least here you do not have a conflict in the vehicle and system targets.
However, on many suspensions it is a lot easier to fulfil the anti-dive than the other two. A case in point is early semi-trailing arms as used on 1970s BMWs: while these had very good anti-dive characteristics, they actually had positive squat, so that under full acceleration the back was diving down quite a bit. Bizarrely the opposite was the case on BMW’s own motorcycles which had more than 100 per cent anti-squat meaning that under full acceleration the rear would actually lift. This is also a trick dragsters use because with more than 100 per cent anti-squat the reaction wants to lift the rear and the counter reaction instantly presses the wheels onto the road improving traction – if only for a short moment, enough to gain an advantage if your whole race only lasts seconds. If you see a top-class dragster seeming to jump up off the start line that is a very good illustration of that effect.
On front-wheel drive cars there is the inherent conflict because for harshness you want the wheel centre to move backwards and for anti-lift you want it to move forwards. Especially on high-powered front-wheel drive cars, getting this balance wrong may result in the front rising unacceptably, the usual remedy being a stiffer chassis setup which clearly has ramifications in other areas.
With the current generally rather stiffer chassis setups – more oriented towards ride-control than ‘plushness’ – and modern electronic chassis control systems one might think that the Antis are of less importance now than they used to be. For example, with modern chassis control systems, dive and to a lesser degree squat can be mitigated by switched (air) springs or controlled dampers. My experience, however, is that the better you have designed the basics of your chassis, the more freedom you have to get the best results out of it by tuning all the rest. In the opposite case, you need to tune and develop around – and compensate for – inherent shortcomings and imperfections in the basics, which often forces you into compromises meaning the resulting car will not be as perfect as you want, given all the effort and machinery invested.
When fully active suspension was seen as the coming thing there was also a belief that then very simple suspensions could be used and all the imperfections would be tuned out by the clever application of the active control. Unfortunately even on concept cars that never turned out to be true and fully active suspensions never made it into volume production. One of the reasons may well be that with a better understanding of the basic systems and geometries of systems engineering and how things work together generally, we managed to deliver much better performance from conventional systems. A typical case of when a new technology is threatening to break through, the established technology gets a boost in development which may or may not allow the new technology to prevail.
The Ford Focus' Control Blade rear suspension exhibited great anti-dive characteristics
Just like with the yaw centre, all this may appear quite complicated when written on the page. However, it is quite easy to feel behind the wheel. Even when quite gently applying the brakes you can feel the front of the car moving down some and the rear of the car possibly moving up. The angle change is even more obvious as the horizon moves up. You may even feel that you are being moved up or down at the beginning or the end of the braking. And with a bit of concentration, you can also feel the pitch centre around which the car dives or conversely pitches. Unlike the yaw centre there’s very little you can do about its location, but nor do you have to.
So now that you have met the Antis, you may appreciate the service they do you every day, as friends, in spite of their less than positive-sounding name.

